In progress
UAV Filmer via Reinforcement Learning
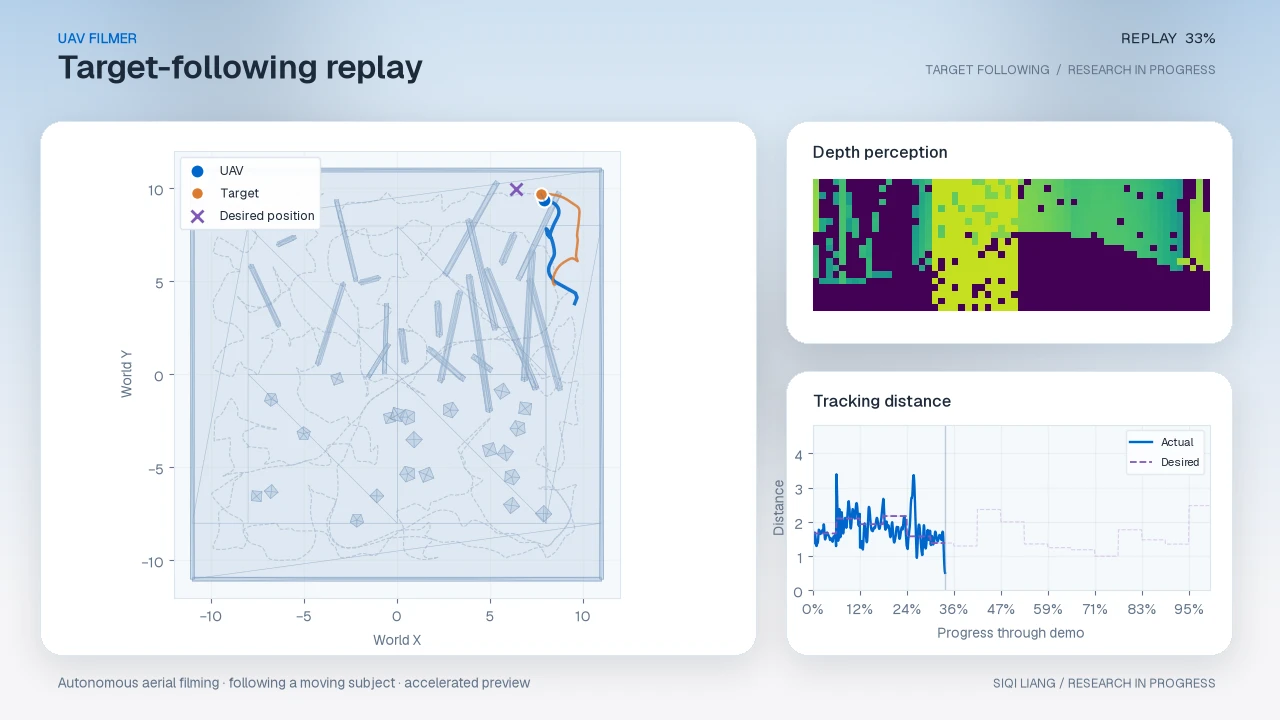
Exploring reinforcement learning for autonomous aerial filming, with the goal of helping a drone follow a moving subject and find suitable viewpoints. Our current work brings together target-following behavior and human-position estimation to support more responsive filming in complex environments.