DALIO: Degeneracy-Aware, Efficient LiDAR-Inertial Odometry With Adaptive Multiresolution Mapping
IEEE/ASME Transactions on Mechatronics
Abstract
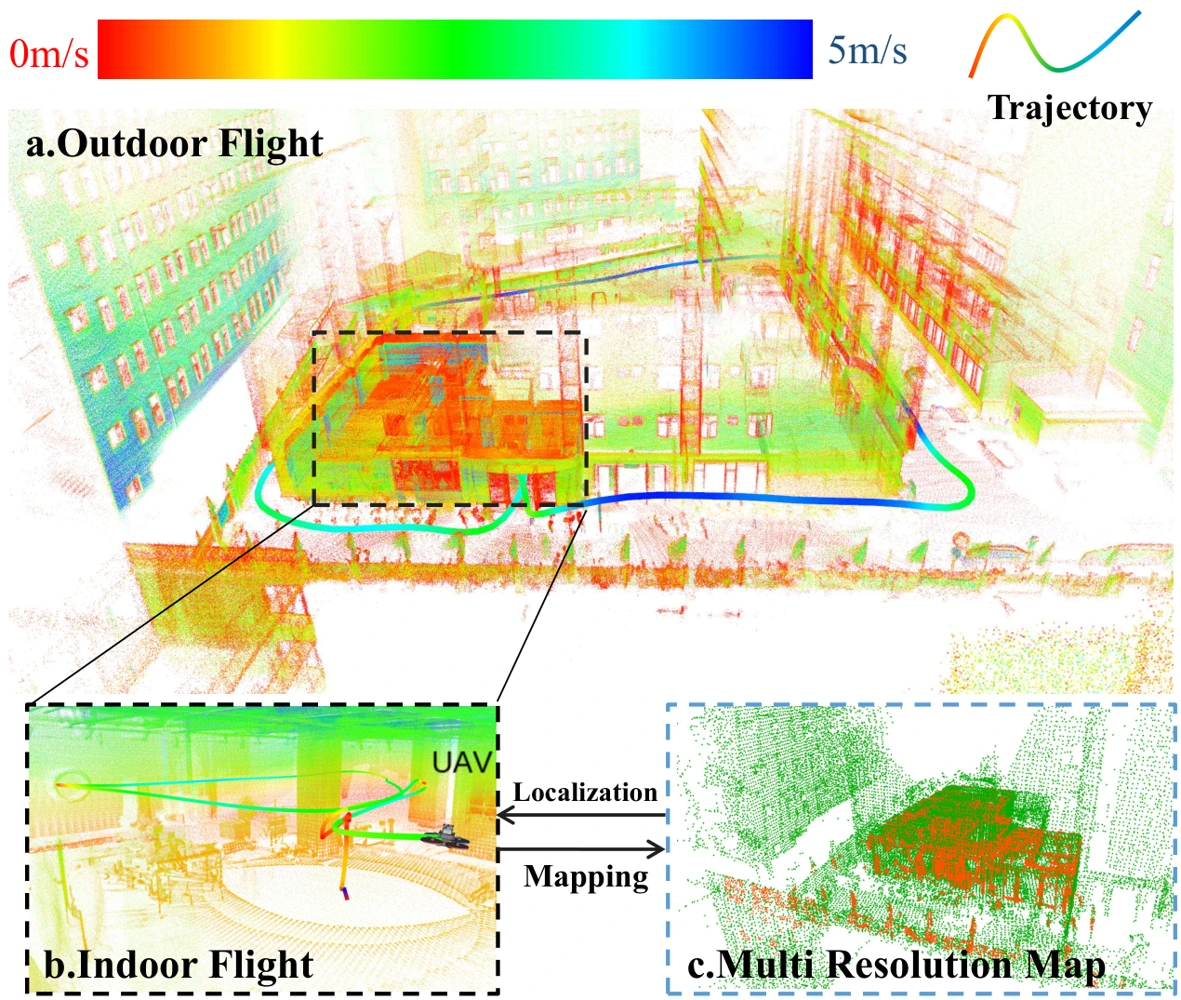
This paper presents DALIO, a novel LiDAR-inertial odometry (LIO) framework that achieves robust localization across diverse environments while significantly reducing computational complexity. Embodying a “Computation on Demand” philosophy, DALIO introduces a degeneracy-aware batch selection module that dynamically adjusts the number of points used for scan registration based on real-time assessments of environmental constraints. Additionally, DALIO incorporates a degeneracy suppression method that filters out the influence of measurements along poorly constrained directions, thereby preventing noise in degenerate modes from corrupting the state update and improving overall estimation stability. Furthermore, DALIO employs MultiMap, an adaptive multi-resolution mapping strategy that preserves essential raw point data while selectively refining map resolution, effectively reducing memory usage and enabling accurate localization in both large-scale and small-scale settings. Extensive evaluations conducted on public datasets, multiple UAV platforms, and resource-constrained embedded systems demonstrate that DALIO achieves localization accuracy comparable to or better than state-of-the-art methods. At the same time, DALIO significantly reduces runtime by up to 65% while maintaining real-time performance across diverse hardware platforms.